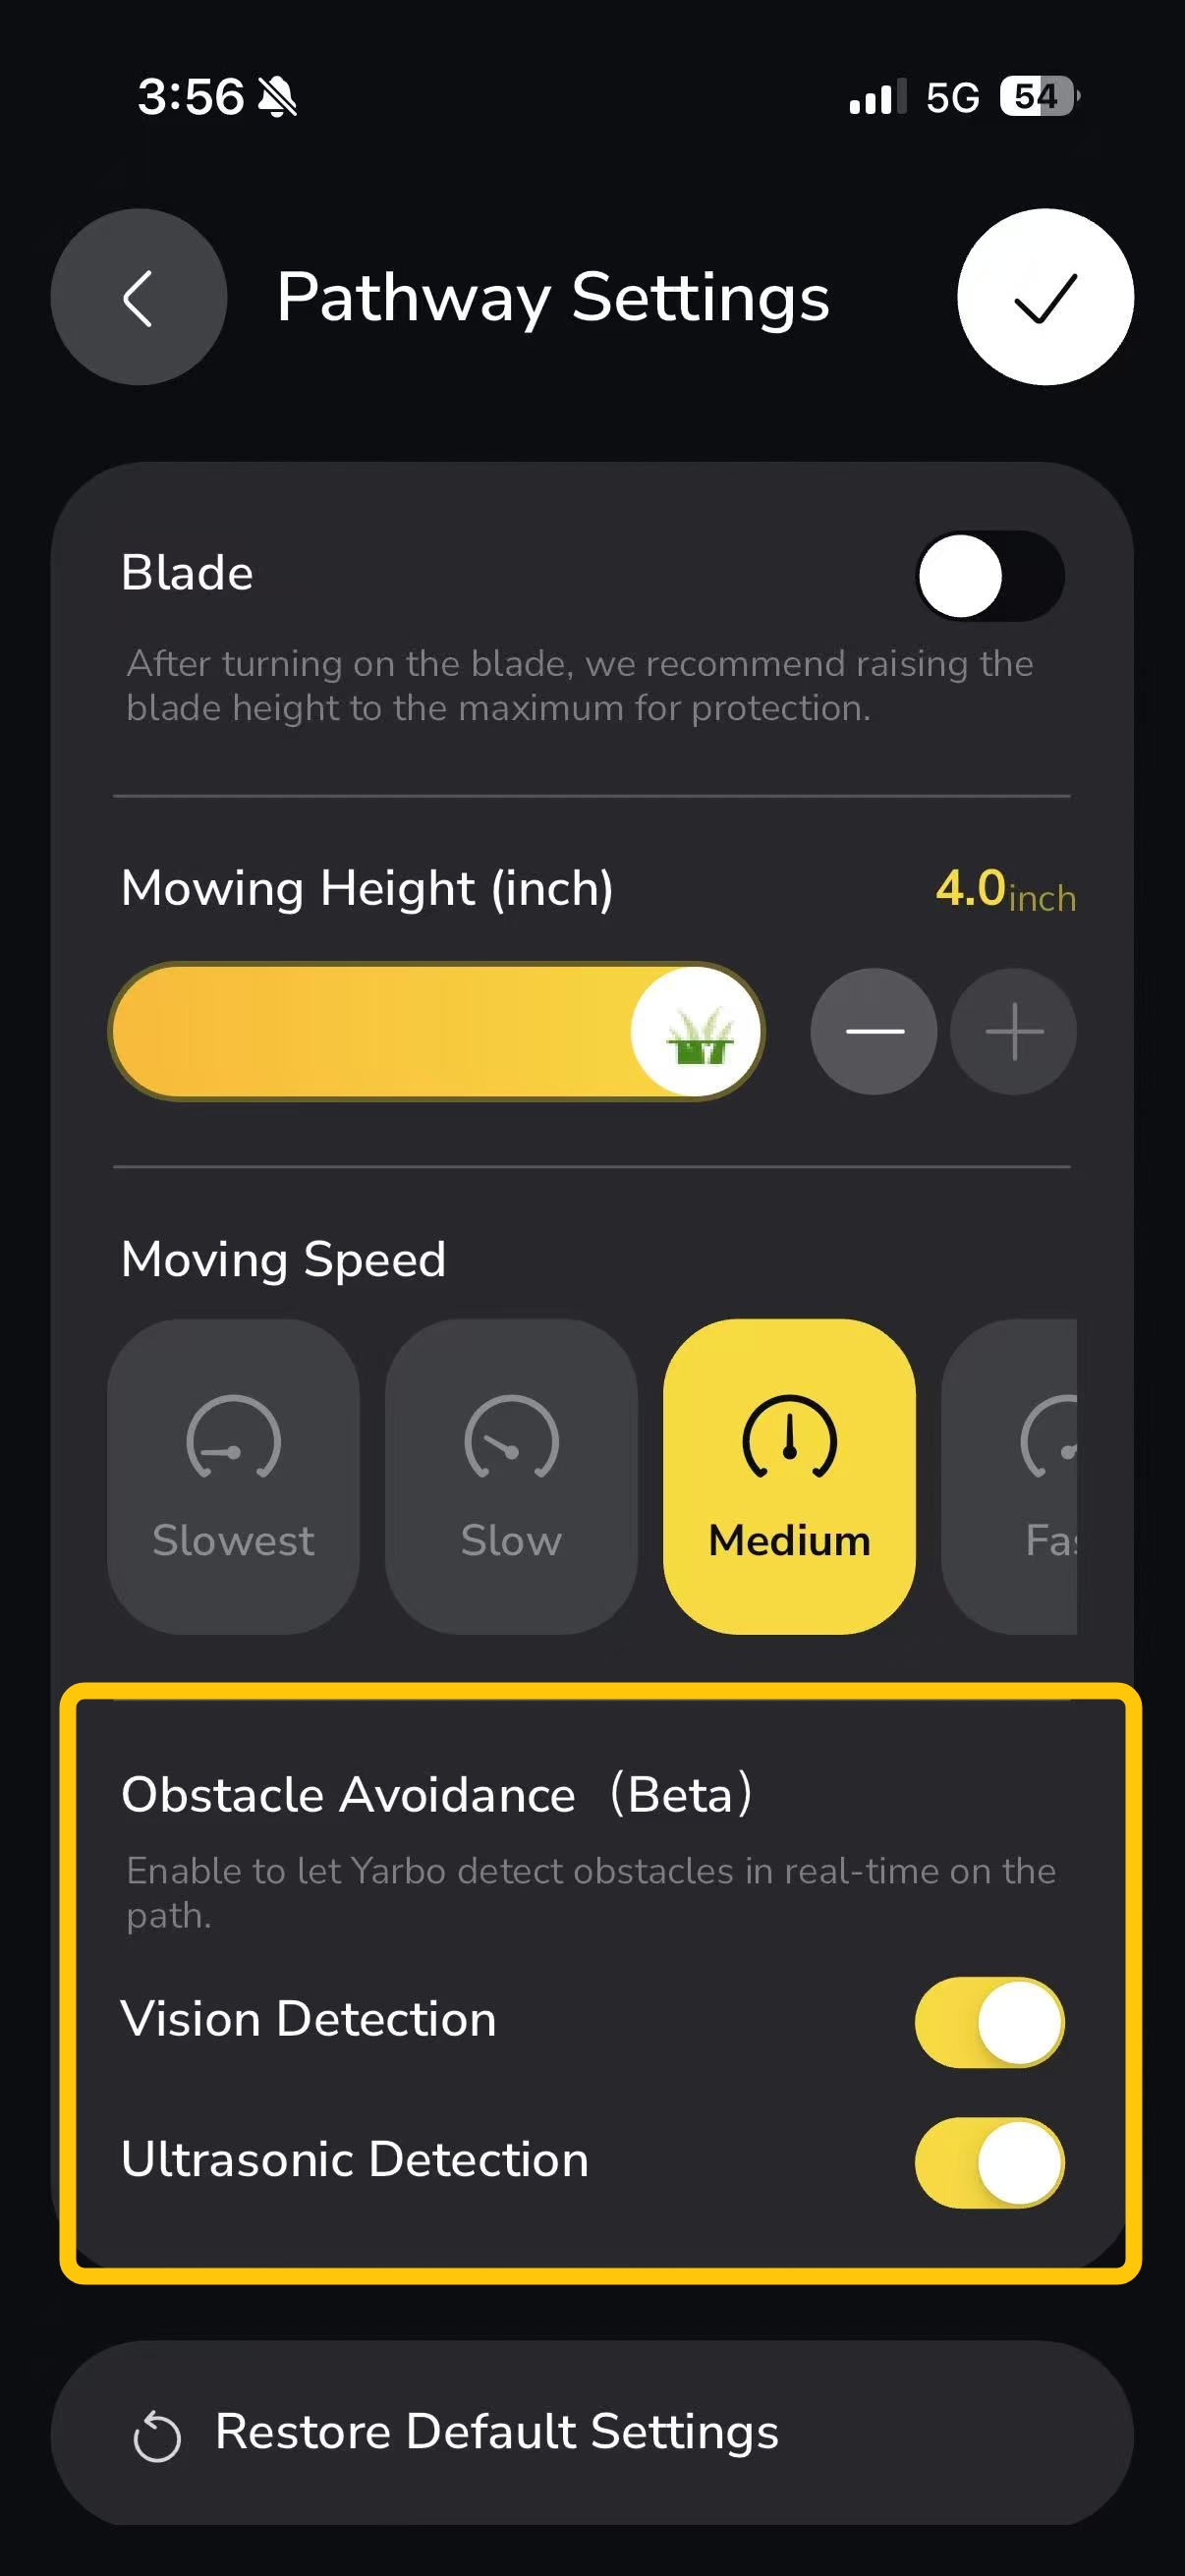
¶ Default Behavior in Work Areas
- In work areas (mowing zones, cleaning zones, etc.), Ultrasonic obstacle avoidance is always enabled by default.
- This ensures Yarbo can effectively detect and respond to unexpected objects such as posts, bins, or other obstacles in general yard environments.
¶ Pathway-Specific Controls
Pathways are often narrower and more complex, with features such as fences, walls, vehicles, or temporary obstructions. To better adapt to these conditions, Yarbo provides individual switches for both:
- Use Vision (camera-based detection)
- Use Ultrasonic (ultrasonic sensor detection)
Users can independently enable or disable each option for pathways depending on their needs.
¶ Why Have Separate Switches?
In some scenarios, constant triggering of false obstacle detection on pathways can cause Yarbo to repeatedly leave the pathway and return, reducing operational efficiency. By allowing users to adjust Visual and Ultrasonic independently, Yarbo provides:
- More precise control in different environments.
- Flexibility to balance between maximum safety and smoother task execution.
¶ Looking Ahead
- Yarbo will continue gathering usage data and feedback to refine how obstacle avoidance works on pathways. The goal is to ensure both reliable obstacle handling and efficient route execution, while still giving users the control they need.